Cobot & AI Vision Fitting Assembly & Inspection Automation
Cobot & AI Vision Fitting Assembly & Inspection Automation
Cobot & AI Vision Based Fitting Assembly & Inspection Automation · Robot SI Reference
Project Overview
A Fitting assembly & inspection automation system based on a smart vision system and a 6-axis articulated collaborative robot. Material fed into the hopper is processed continuously through automatic alignment → feeding → robot transfer; the robot picks up the workpiece, seats it in the assembly jig, assembles the fitting, and inspects the assembly with AI vision. Finished products are automatically discharged and stacked, achieving fully unmanned operation from material loading to discharge.
Automation System Configuration
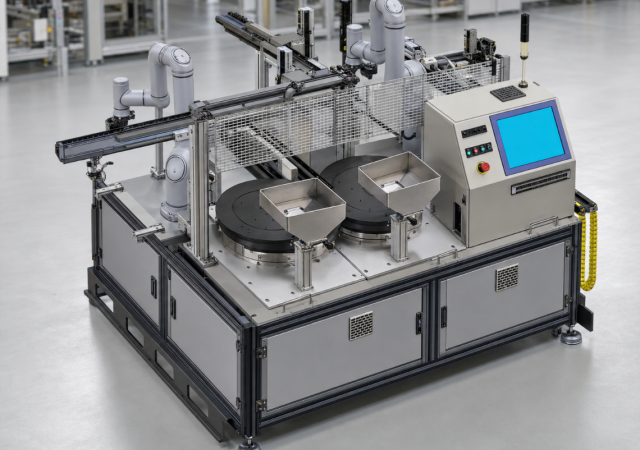
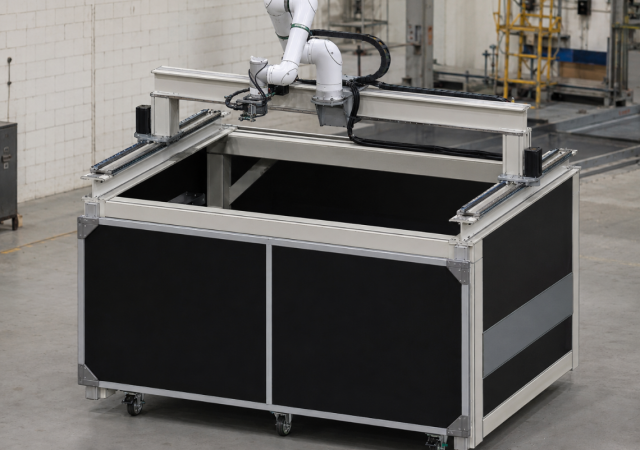
 ▲ Fitting assembly & inspection cell based on a 6-axis collaborative robot + AI vision
Process Flow
Material Loading
An operator loads the workpieces (fitting parts) into the hopper. The subsequent processes then run continuously and unattended.
Hopper Alignment & Automatic Feeding
A vibratory hopper aligns the parts in a consistent orientation and automatically feeds them one at a time to the next process.
Robot Pick-up & Jig Seating
A servo Cartesian robot and a 6-axis collaborative robot precisely pick up the parts and seat them accurately in the assembly jig. Seating precision determines the assembly quality.
Precision Fitting Assembly
Fitting parts are precisely assembled onto the workpiece seated in the jig. A cylinder / interlock structure fixes the assembly position to ensure repeatable precision.
AI Vision Inspection
A camera-based vision system identifies the part type / orientation and the assembly condition. It compares against reference images to automatically sort out defective products and prevent defect outflow.
Automatic Discharge & Stacking
The collaborative robot picks up the inspected finished products and automatically discharges and stacks them. SCADA monitors the entire process in real time to support stable unmanned operation.
Equipment Configuration & Specifications
| Category | Item | Specification · Configuration |
| Basic Specs |
Equipment Size | 1,800 (W) × 1,800 (D) mm |
| Throughput | Within 10 sec max (cycle time) | |
| Rated Power | AC 220V, 30A | |
| Operating Pressure (Pneumatic) | 0.5 ~ 0.7 MPa | |
| Operating Temperature | 5 ~ 40 ℃ | |
| Main Components |
Collaborative Robot | 6-axis articulated cobot — product loading / unloading, inter-process transfer & discharge |
| Cartesian Robot | Servo Cartesian (X·Y·Z) — precise part pick-up & transfer | |
| Hopper | Vibratory alignment & automatic feeding of parts | |
| Vision System | AI vision — identifies part type / orientation & assembly condition | |
| Control System | SCADA + electrical / control — integrated operation and real-time monitoring | |
| Safety Devices |
Interlock Cell | Door interlock · emergency stop (EMG) · safety cover — ensures operator safety |
Benefits
- Fully unmanned automation from material loading through alignment, assembly, inspection, and discharge
- Real-time AI vision inspection blocks defect outflow at the source and uniformizes assembly quality
- Collaborative-robot safe cooperation minimizes fencing and saves installation space
- Cycle time within 10 seconds maximizes productivity
- SCADA integrated monitoring provides alarm / history management and stable operation
Applications
- Fitting assembly & inspection automation lines
- Small precision part assembly & handling processes
- Vision-based appearance / shape / assembly inspection automation
- Flexible automation cells for high-mix, low-volume production
- Products where uniform assembly quality and defect control are critical